All posts
EasyDriver + Stepper Motor with Arduino
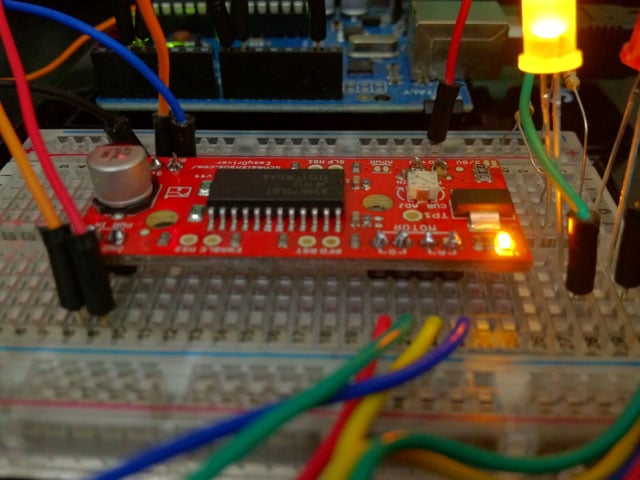
Today was a busy shopping day in Deira, Dubai. Finally found a location where I can buy electronic stuffs like resistors, capacitors, LED etc. The things I bought today was
- Regulated Power Supply
- Soldering Station
Once I was home, I started to solder the EasyDriver Stepper Motor Driver.
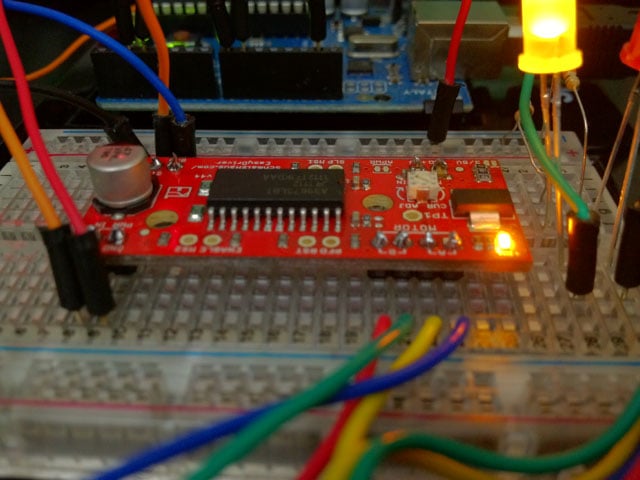
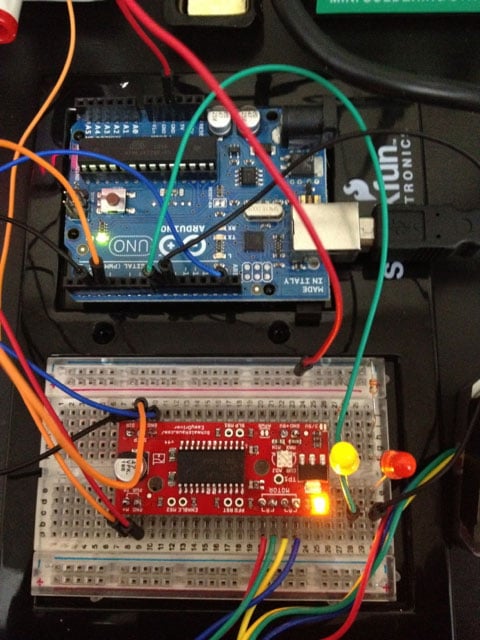
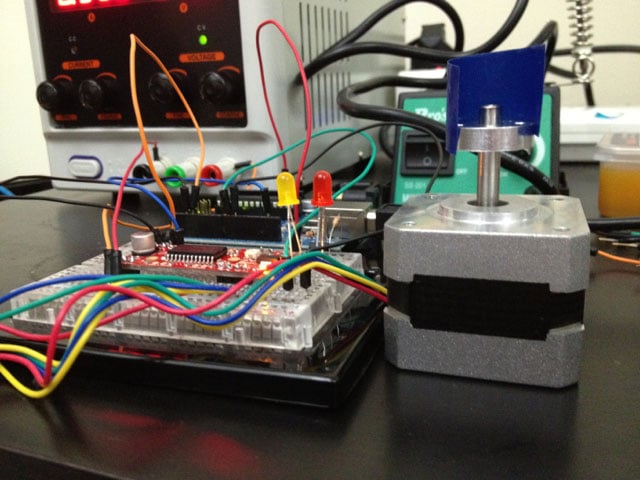
Basically I soldered few male header so I can fix the EasyDriver board easily to a bread board. Then connected the Stepper Motor to the driver board and needed connection to Arduino board.
#define DIR_PIN 2
#define STEP_PIN 3

int rotation=0;
int direction = 1;
int ledYellowPin =  8;
int ledRedPin =  9;

void setup() {
  pinMode(DIR_PIN, OUTPUT);
  pinMode(STEP_PIN, OUTPUT);
  pinMode(ledYellowPin, OUTPUT);
  pinMode(ledRedPin, OUTPUT);
}

void loop(){
  rotation++;
  if(rotation==10){
    direction = direction * -1;
    rotation = 0;
    digitalWrite(ledYellowPin, HIGH);
    digitalWrite(ledRedPin, HIGH);
    delay(1000);
    digitalWrite(ledYellowPin, LOW);
    digitalWrite(ledRedPin, LOW);
    delay(1000);
    digitalWrite(ledYellowPin, HIGH);
    digitalWrite(ledRedPin, HIGH);
    delay(1000);
    digitalWrite(ledYellowPin, LOW);
    digitalWrite(ledRedPin, LOW);
    delay(1000);
  }
  if(direction>0){
    digitalWrite(ledYellowPin, HIGH);
    digitalWrite(ledRedPin, LOW);
  }else{
    digitalWrite(ledYellowPin,LOW);
    digitalWrite(ledRedPin,  HIGH);
  }
  rotateDeg(direction * 360, 1.0);
}

void rotateDeg(float deg, float speed){
  int dir = (deg > 0)? HIGH:LOW;
  digitalWrite(DIR_PIN,dir);
  int steps = abs(deg)*(1/0.225);
  float usDelay = (1/speed) * 70;
  for(int i=0; i < steps; i++){
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(usDelay);
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(usDelay);
  }
}
Reference: Use The EasyDriver Stepper Motor Driver + Arduino, Blink
- Category
- Tags
Discussion
No comments yet